


UMich team works on perception and localization using cameras
Submitted by brad on Sat, 2015-01-24 12:24Some new results from the NGV Team at the University of Michigan describe different approaches for perception (detecting obstacles on the road) and localizations (figuring out precisely where you are.) Ford helped fund some of the research so they issued press releases about it and got some media stories. Here's a look at what they propose.
Topic:

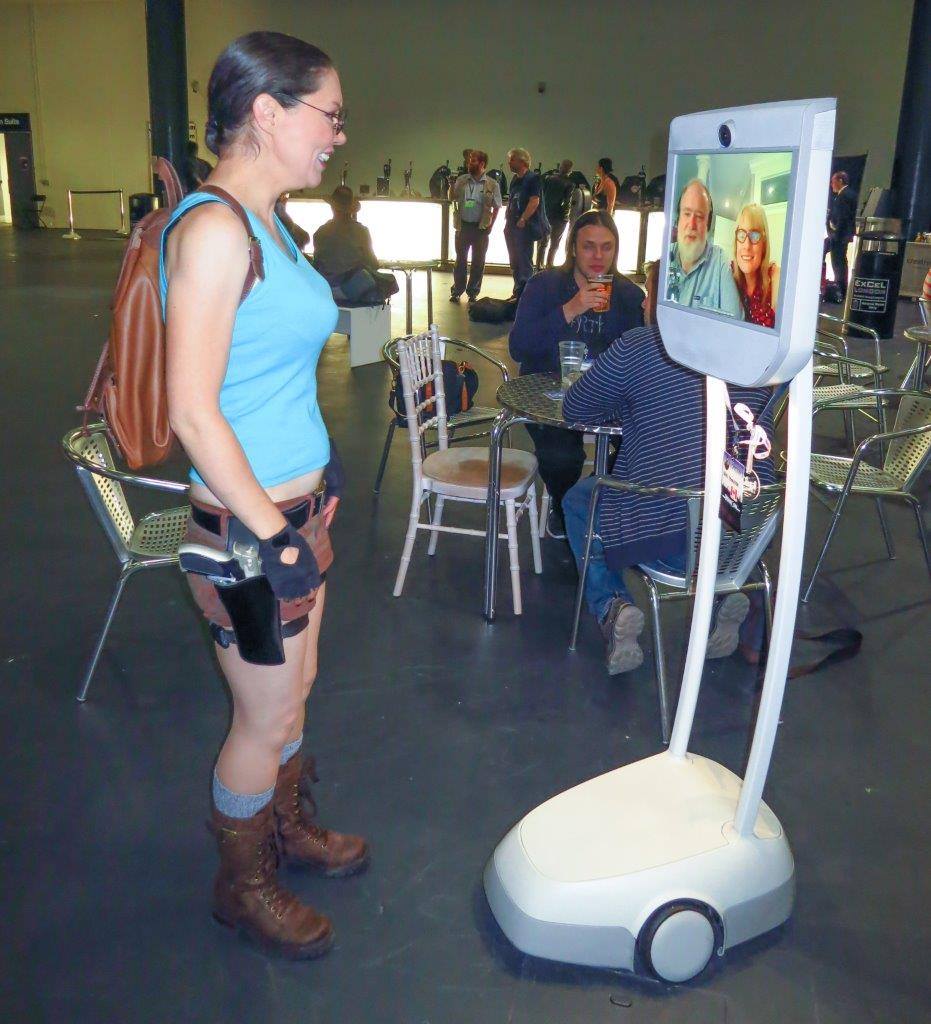 In August, I attended the World Science Fiction Convention (WorldCon) in London. I did it while in Coeur D'Alene, Idaho by means of a remote Telepresence Robot(*). The WorldCon is half conference, half party, and I was fully involved -- telepresent there for around 10 hours a day for 3 days, attending sessions, asking questions, going to parties. Back in Idaho I was speaking at a local robotics conference, but I also attended a meeting back at the office using an identical device while I was there.